5-axis Arm Robot Trainer ED-7255

Cod: ED-7255


Brosura produs PDF, 0.47 Mb

Descriere

EXPERIMENTS

  • Introduction to the System
    • Basic Configuration
    • Description of components
    • Overview of Program
    • Architecture
    • Installation
  • Program Composition
    • Menu and Toolbar
    • View and Windows
    • Simulator and Screen control
    • Industrial language editor
  • Arm Viewer and Robot Manipulation
    • How to use "3D Arm Viewer"
    • Manual mode for controlling the robot
    • Storage and utilization of the position data
  • Programming
    • How to use Program Editor
    • Program syntax
    • Programming
    • Program execution and debugging
  • Robot Simulation
    • Virtual simulation and robot manipulation methods
    • Basic experiments 1
    • Basic experiments 2
    • Basic experiments 3
  • Robot Control Basic Experiment
    • Position transfer methods
    • Velocity transfer methods
    • Position determination methods
    • How to use "Teach Pendant"
  • Applications for Robot Manipulation
    • Accurate transfer through block repetitions
    • Grip and transfer for a certain object
    • Position transfer for a certain object
    • Repetitive operation and simulation-linked transfer


Features:

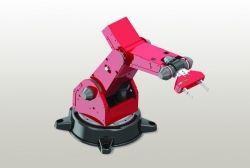
  • Consists of one gripper and 5-axis vertical multi joints
  • Absolute-type RVDT Position Sensor applied to each axis and requires no Limit switch
  • High performance CPU enables real-time control of each axis
  • PID gain tuning and real-time control
  • Emergency switch on the robot controller and teaching pendant
  • Control by USB and Ethernet interface
  • Expandible 2-axis and digital or analog I/O port
  • 3D graphic simulation and real-time connectivity with a real robot


Alte produse ED

TELECOMMUNICATION TRAINER ED-2960

• 7 experimental modules with a mainframe console
• Harmonic Analysis and Superheterodyne Receiver experiments
• PCM(TDM), Sample Hold, and Delta Modulation experiments


RFID APPLICATION TRAINER ED-3100

• Various types of test point for Air-interface experiments
• Anti-collision function
• OCX Library useful for application engineers
• 13.56MHz I-CODE Type in common usage
• Capability of reading and writing data on Tag


SIEMENS SIMATIC STEP7-300 MODULAR PLC TRAINER ED-4260S

• SIMATIC STEP7-300 PLC programming and execution
• Modularization of the devices dssential for PLC I/O commands
• Experiments for basic command and various application program
• Binary data experiments with 4digits digital switch and display unit
• Customizable for various types of STEP7-300 series CPU


6-AXIS MULTI JOINT ROBOT TRAINER ED-VP6

• Experiments on the industrial robot being used in real life
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


5-AXIS ARM ROBOT TRAINER ED-7255

• Consists of one gripper and 5-axis vertical multi joints
• Absolute-type RVDT Position Sensor applied to each axis and requires no Limit switch
• High performance CPU enables real-time control of each axis
• PID gain tuning and real-time control


PC BASED DIGITAL COMMUNICATION TRAINER ED-1440

• The Electronic Manual operable on PC comes with ED-1440 and e-learning is optimized by remote control of student’s operating program and evaluation of student’s online peport in real time.
• Through DS-1410, it provides Variable Power Supply(VPS), Function Generator(FG), Analog Output, Digital Output needed for experiments.


PC BASED ANALOG COMMUNICATION TRAINER ED-1460

• Interlocking system package with CBIS-1400 and DS-1410 Models (Options)
• Experiments on a measurable low frequency bandwidth
• Realistic experiments on modulation and demodulation
• Verification of the output waveform on PC engaged with CBIS-1400 Model


ASSEMBLING ROBOT TRAINER ED-7300

• Disassembly and assembly practices for the robot actuators
• Utilization of a robot being used in the industry, so to apply a job site after graduation
• Simulation software provided to make assembly or disassembly easily
• Enables basic operation and testing practices on the assembled unit using a controller


INVERTER TRAINER ED-4280M

• Aluminum hard case structure for mobility
• Applied experiments on the motor’s rotation characteristics
• AC motor control technology using the inverter
• Interlocking experiments with Programmable Logic Controller


PULSE/DIGITAL COMMUNICATION TRAINER ED-2920

• Modularized by each communicarion type
• PAM, PTM, PCM, DPCM, ADPCM, LDM, ADM, Delta-sigma
• No need to have additional generators (built-in power supply and signal source)
• Can display the test point and measure signals using an oscilloscope