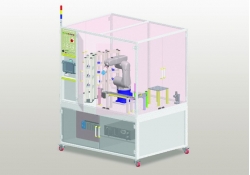
4-axis Rectangular Coordinates Robot Trainer ED-XYZ

Code: ED-XYZ


Datasheet PDF, 0.41 Mb

Description

EXPERIMENTS

  • Characteristics of the Rectangular Coordinates robot
  • Language of the Industrial robot
  • Point-to-point transfer program
  • Palletizing experiments
  • Interlocking experiments with other automation system
  • Control by the 3D simulation program


Features:

  • Experiments on the 4-axis Cartesian robot
  • Teaching pendant in 7.5wide color touch panel
  • Standard language for the international industrial robot
  • Simulation software in three dimension
  • Ethernet communication as standard, and network with PC
  • Interlocking experiments with the automation system
 

More products ED

DC MOTOR/ GENERATOR MG-5211

• Load characteristics of DC compound motor
• Cumulative compound and differential compound characteristics
• Generator’s rotating speed and output characteristics
• Loss and efficiency of DC compound generator


UBIQUITOUS SENSOR NETWORK TRAINER ED-3160

• The optional Embedded System(ED-255EK) can be linked as a gateway
• ZigBee network can be built using TinyOS, F8WOS
• Capable of control and monitor through Ethernet
• The RFID Card Reader is supplied as a standard shipped component for applied experiments on security, home automation and robot


DC SERVO MOTOR TRAINER ED-4302

• Display of the rotational speed and angle data using LCD
• PC control and waveform output functions
• Portable type with Aluminum Carrying Case


REFRIGERATION & AIR CONDITIONING DEMONSTRATOR ED-5820/ED-5840

• Easy-to-use demonstarator for principles of refrigeration/airconditioning
• Motor Compressor : Pison type
• Trouble shooting for pipe leakage


PNEUMATICS TRAINER ED-7860

• Convenient parts fixation by ‘one-touch lever’ bases and aluminum profile structure
• Efficient space utilization by mounting parts horizontally/vertically
• A complete pneumatic training system to help achieve advanced level of skills and obtain pneumatic engineering related licensesOver


SYNCHRONOUS MOTOR(3-PHASE)/DC GENERATOR MG-5215

• Start and Sync characteristics of synchronous motor
• V-curve characteristics of synchronous motor
• Synchronous motor’s loss and efficiency
• Load characteristics of self-excited shunt-wound generator


DC MOTOR/AC GENERATOR MG-5214

• DC motor’s load characteristics
• DC motor’s loss and efficiency
• Alteration of the motor’s rotative directions
• Motor’s speed and torque


PC BASED ANALOG COMMUNICATION TRAINER ED-1460

• Interlocking system package with CBIS-1400 and DS-1410 Models (Options)
• Experiments on a measurable low frequency bandwidth
• Realistic experiments on modulation and demodulation
• Verification of the output waveform on PC engaged with CBIS-1400 Model


MOTOR / GENERATOR TRAINER UNIT MG-5216

• RIM’s no-load power factor and load power factor
• Load characteristics of separately excited DC shunt-wound generator
• No-load saturation characteristics of generator
• DC shunt-wound generator’s loss and power factor


6-AXIS MULTI JOINT ROBOT TRAINER ED-VP6

• Experiments on the industrial robot being used in real life
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension