Electronic Communication Trainer ED-2950

Code: ED-2950


Datasheet PDF, 0.55 Mb

Description

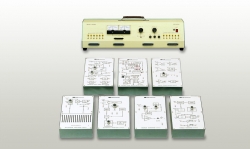
CONSOLE (MAIN FRAME) ED-2900(P)

  • DC Output(Regulated) : 0~20V (3A), 15V (1A), 5V (2A) (Unregulated) : +50V (0.5A)
  • AC Output : Selectable : 5/10/15/20V, Fixed : 20V(0.5A)
  • Indicator : Voltmeter(4 ranges), Current Meter
  • Module Connection Capacity : 4 Modules
  • Input Voltage : AC 220V, 50/60Hz
  • Dimension : 710(W) x 190(H) x 195(D)mm
  • Weight : 12.7kg

GENERAL CHARACTERISTICS

  • Module Dimension : 166(W) x 65(H) x 250(D)mm
  • System Weight : 10kg 

ACCESSORIES

  • Connection Cord(ø2 plug) : 1set
  • AC Power Cord : 1ea
  • Operating Manual : 1ea
  • Experimental Manual : 1ea

Features:

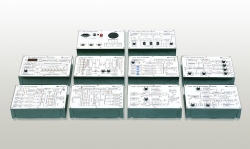
  • 10 experimental modules with a mainframe console
  • Basic concepts on the communication systems
  • Experiments on the broadcast frequency band tuning
  • Generation of AM and FM waves and detection theory


More products ED

MOTOR / DYNAMOMETER TRAINER UNIT MG-5219

• Measurement of induction motor’s power efficiency
• How to use electro-dynamometer
• Torque Measurements by dynamometer
• Use of separately excited DC generator


DC SERVO MOTOR TRAINER ED-4302

• Display of the rotational speed and angle data using LCD
• PC control and waveform output functions
• Portable type with Aluminum Carrying Case


MITSUBISHI MELSEC-Q MODULAR PLC TRAINER ED-4260M

• MITSUBISHI MELSEC-Q PLC programming and execution
• Modularization of the devices essential for PLC I/O commands
• Experiments for basic command and various application program
• Binary data experiments with 4digits digital switch and display unit
• Various types of QCPU can be selected from a basic to hyper performance


4-AXIS RECTANGULAR COORDINATES ROBOT TRAINER ED-XYZ

• Experiments on the 4-axis Cartesian robot
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


INTELLIGENT ROBOT DEVELOPMENT KIT ED-7273

• Obstacle avoidance and autonomous traveling using eight ultrasonic sensors
• Various types of robot configuration by combining each module
• Remote control by the controller
• Precise operation by DC Servo Motor
• Flow chart based programming software


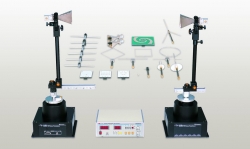
ANTENNA TRAINER ED-3200

• 16 different types of Antenna
• RF source generation : 500MHz, 2GHz and 10GHz
• Software simulation of radiation Patterns and characteristics of Antenna
• Antenna Directional Coupler (Manual / Remote)


TELECOMMUNICATION TRAINER ED-2960

• 7 experimental modules with a mainframe console
• Harmonic Analysis and Superheterodyne Receiver experiments
• PCM(TDM), Sample Hold, and Delta Modulation experiments


SMALL DESKTOP TYPE PLC TRAINER ED-4260MD

• Small desk type structure for space optimization
• Built-in DC power supply for convenience
• Handy experiments on the basic and application programming commands
• Base structure capable of expansion by mounting the special modules


STEPPING MOTOR TRAINER ED-4301

• Graphical display of functonal block diagram on the system suface
• Real-time monitoring and control by PC Control Program
• LM Guide and Rotary Encoder for position control
• Displays moving distance and angle data using LCD


MULTIPLEXED COMMUNICATION TRAINER ED-2990

• PLL and Digital Synthesizer
• PAM, PCM, FDM and FSK Modem
• 10types of module including DC Power Supply